A layered diagnostic for stale LiDAR obstacles in Nav2, connecting fresh observations and clearing-ray geometry to a reproducible place-and-remove test.
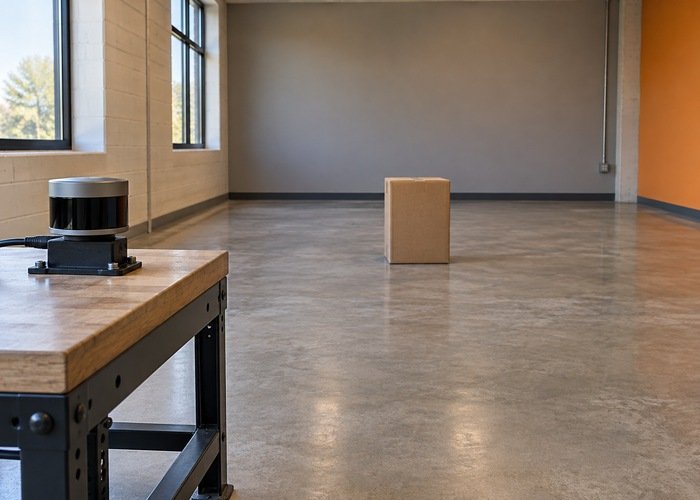

A layered diagnostic for stale LiDAR obstacles in Nav2, connecting fresh observations and clearing-ray geometry to a reproducible place-and-remove test.
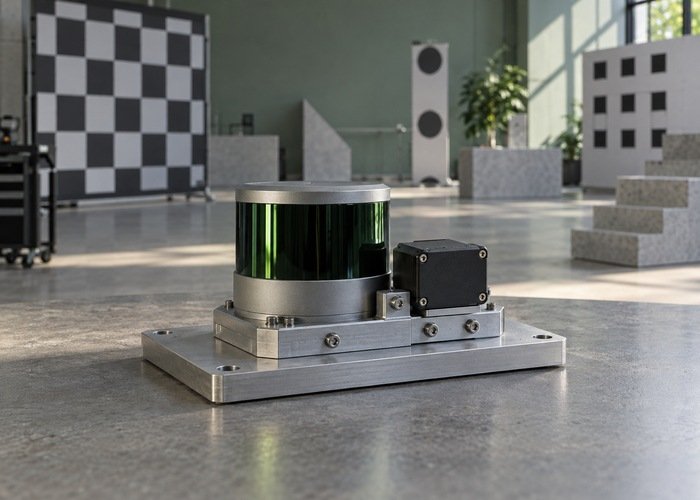
A capture-sufficiency worksheet for LiDAR–IMU initialization, with method-specific excitation feedback and independent validation of a frozen calibration result.
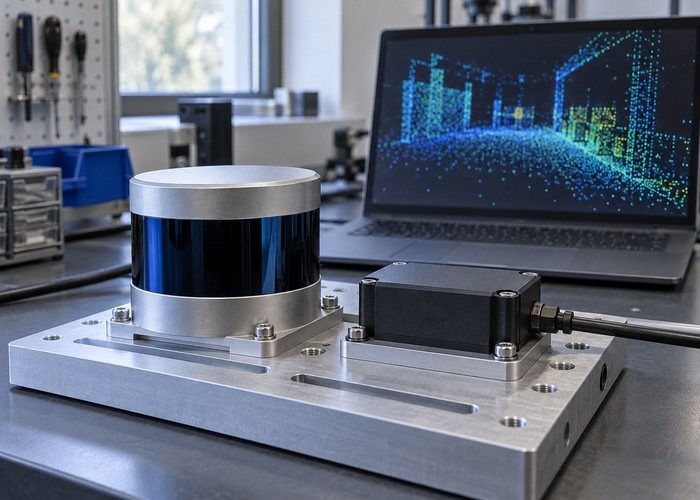
A practical field-contract worksheet and repeat-test procedure for diagnosing FAST-LIO motion smear caused by incorrect point-time interpretation.
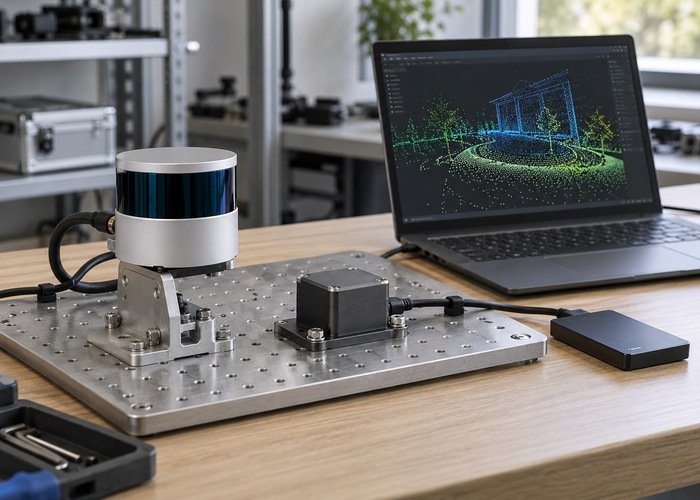
A field-contract and replay checklist for preserving per-point timing when recording LiDAR and IMU messages.
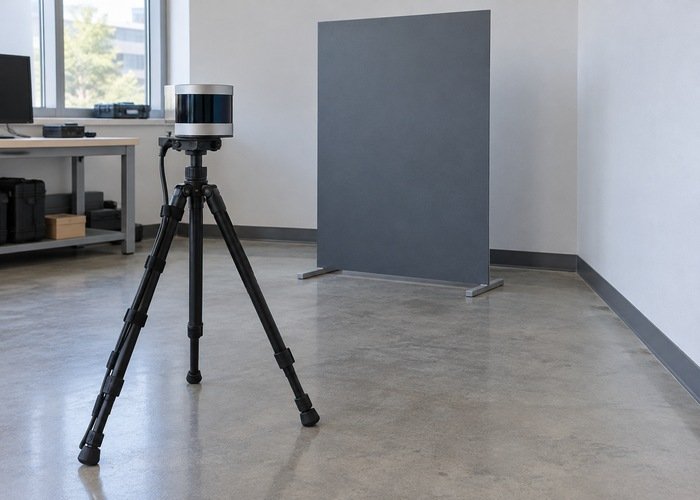
A fixed-scene procedure that separates point-cloud display persistence, scan batching and missing measurements.
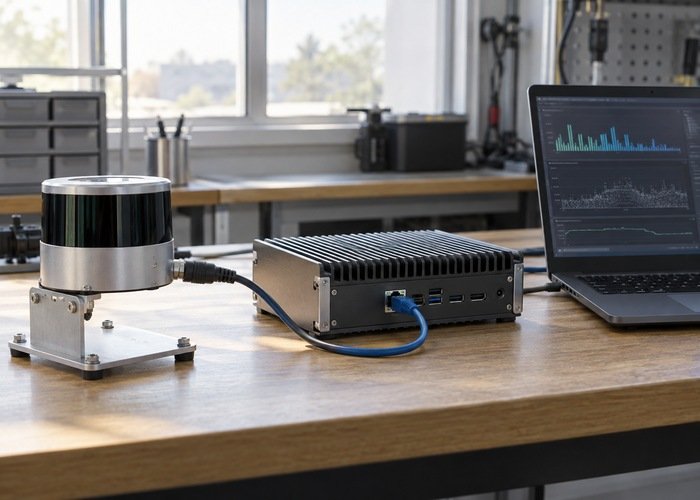
A controlled measurement worksheet for LiDAR packet arrival, cloud publication, subscriber reception and completed processing.
Inspect endpoint policies and test compatible reception before treating a silent ROS 2 LiDAR subscriber as a sensor failure.
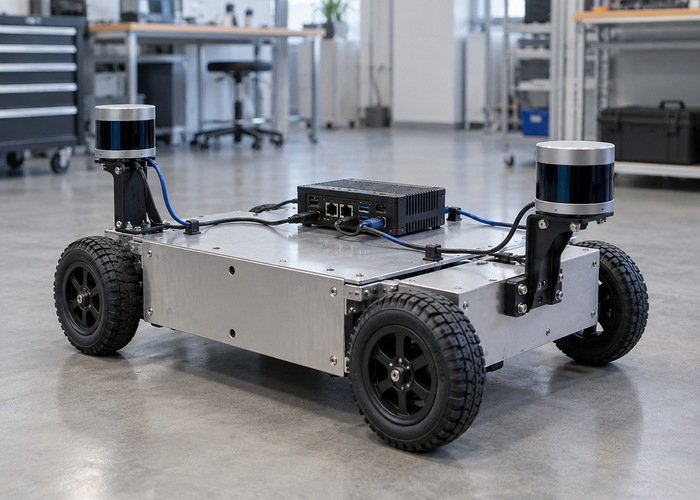
An address, routing and sensor-identity checklist for two Ethernet LiDARs connected to independent host interfaces.
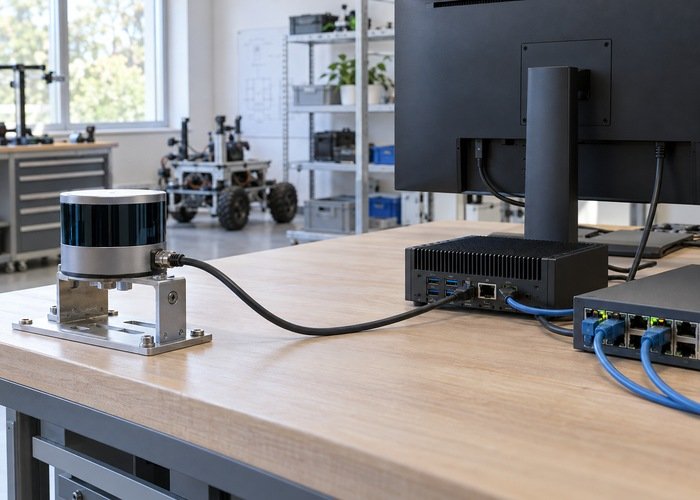
A practical diagnostic path for LiDAR data that appears in a viewer but does not reach the ROS driver.
lidar in robotics practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
 Robotic Dog-E1 Series
 Robotic Dog-S1 Series


