Trace gyro units from native IMU output to ROS angular_velocity, verify conversion once and keep angular-velocity covariance consistent before fusion tuning.

Compare relative and differential robot_localization pose handling, initial references, velocity conversion and restart behavior without hiding input provenance.
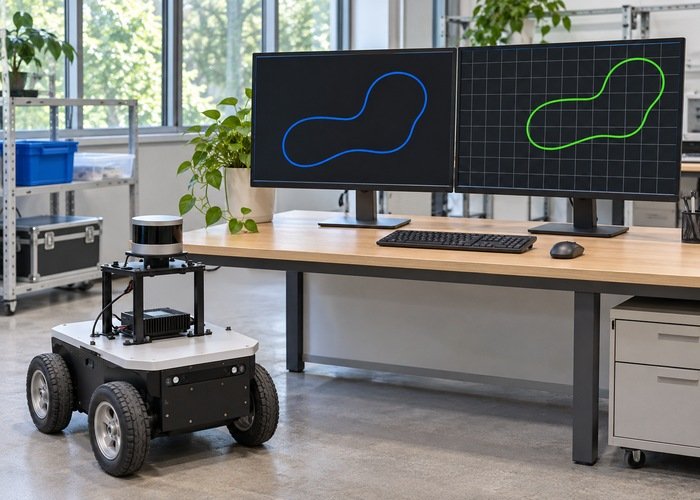
Audit robot_localization world_frame, continuous local odometry and global position corrections before changing transforms or fusion tuning on a LiDAR robot.
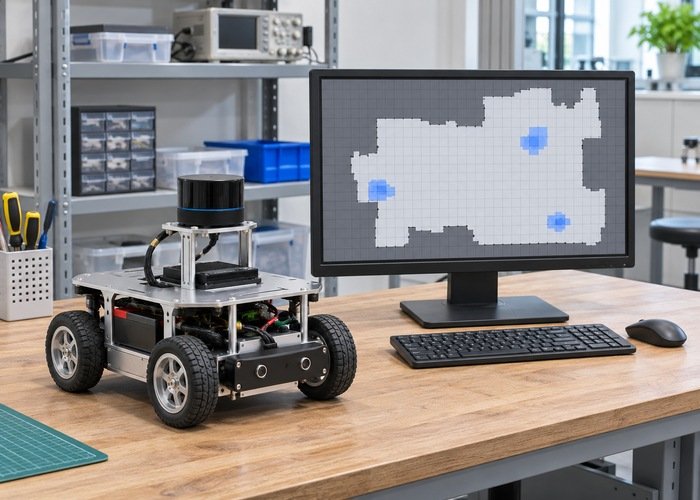
Separate Nav2 costmap update cadence from published visualization traffic before changing frequencies, full-map settings or LiDAR pipeline parameters.
Audit LiDAR ring and timestamp fields through PCL voxel filtering, point-type conversion and aggregation before passing downsampled clouds to another consumer.
Diagnose a recorded map missing during rosbag2 playback by separating bag contents, playback QoS, subscriber startup order and publisher lifetime.
Trace invalid LiDAR coordinates through PCL cleanup, verify the is_dense flag, preserve point indices and test the actual finite-value filtering path.
A practical workflow for locating incorrect camera color interpretation across drivers, bridges and display consumers.
Diagnose ignored LiDAR parameter files by checking actual paths, node names, YAML scope, declared types and running-node parameter readbacks.
Check Jetson camera frame-rate drops using the selected sensor mode, effective exposure controls, capture metadata and identified timing boundaries.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
 Robotic Dog-E1 Series
 Robotic Dog-S1 Series


