Frame triggering does not establish a shared LiDAR clock. Build an event contract, inspect the supported FSYNC path and verify capture alignment separately from host arrival.
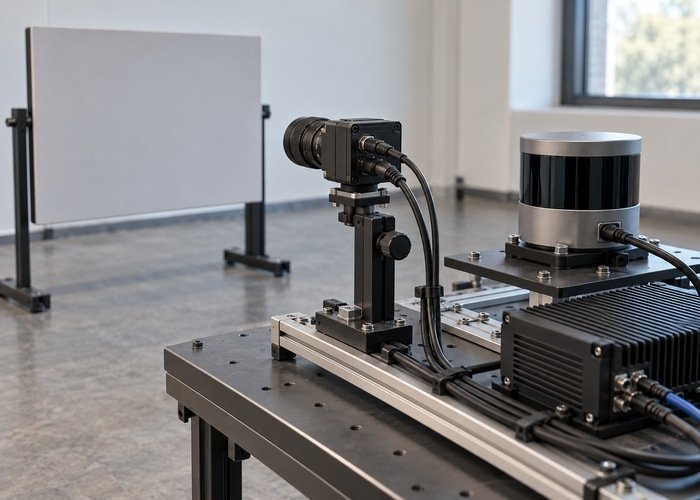

Frame triggering does not establish a shared LiDAR clock. Build an event contract, inspect the supported FSYNC path and verify capture alignment separately from host arrival.
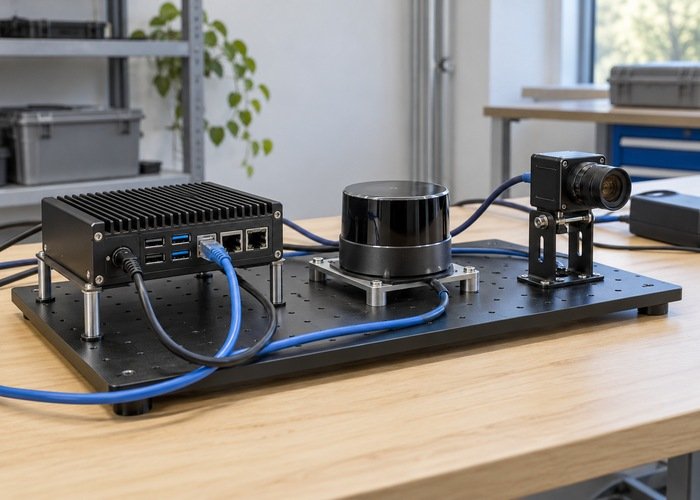
Freeze the complete sensing stack before a JetPack upgrade. Compare identified builds, validate live sensors and consumers, and demonstrate recovery before deployment.
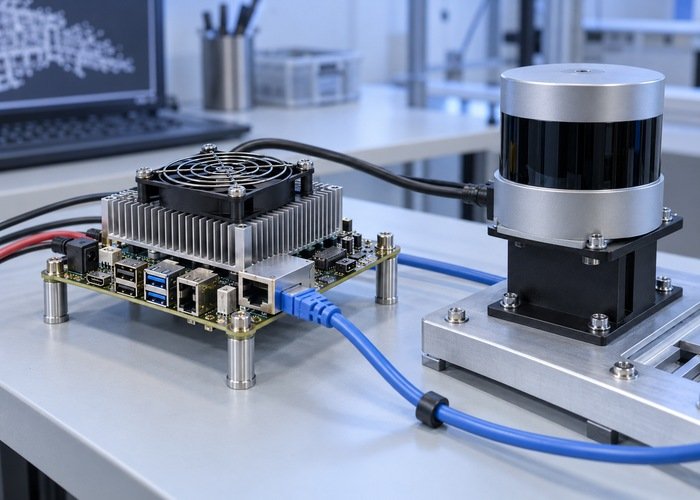
A cold-versus-sustained workload experiment for investigating Jetson LiDAR latency without assuming every warm slowdown is thermal throttling.
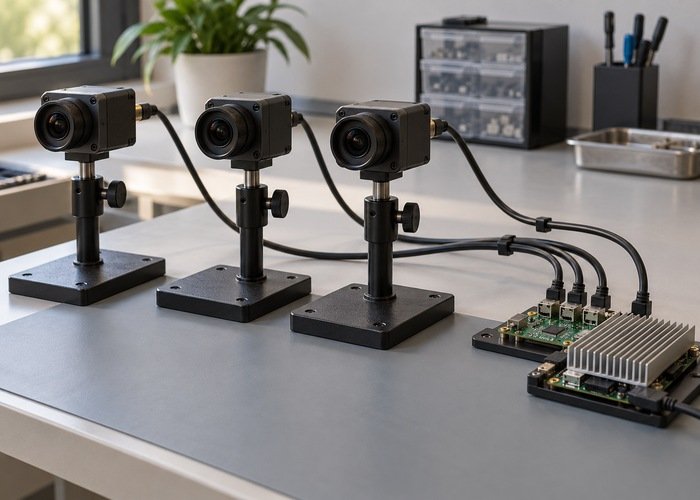
A route-by-route CSI and downstream workload budget with explicitly illustrative calculations and a concurrent camera-capture validation matrix.
A runtime comparison matrix and replayable evidence package for GMSL cameras that capture through V4L2 but fail in the intended Argus path.
A physical-to-logical route worksheet and distinct-target test for two GMSL cameras that appear to produce the same stream.
A pre-order compatibility worksheet connecting GMSL hardware identities, Jetson carrier support, release-pinned BSP packages and application-level capture evidence.
nvidia jetson carrier board practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
jetson carrier board practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
nvidia jetson carrier board practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
 Robotic Dog-E1 Series
 Robotic Dog-S1 Series


