Diagnose ignored LiDAR parameter files by checking actual paths, node names, YAML scope, declared types and running-node parameter readbacks.
Diagnose ignored LiDAR parameter files by checking actual paths, node names, YAML scope, declared types and running-node parameter readbacks.
Separate sensor delivery from blocked application execution and repair synchronous-service dependency cycles with explicit callback ownership.
Trace a Nav2 speed restriction from mask encoding through filter metadata and SpeedLimit messages to controller output.
A practical workflow for diagnosing custom PointCloud2 decoders using preserved bytes, explicit field dictionaries and bounded comparisons.
A boundary-by-boundary diagnostic for a valid PointCloud2 that never produces Nav2 occupied cells, with a stationary target test and evidence worksheet.
A layered diagnostic for stale LiDAR obstacles in Nav2, connecting fresh observations and clearing-ray geometry to a reproducible place-and-remove test.
A field-contract and replay checklist for preserving per-point timing when recording LiDAR and IMU messages.
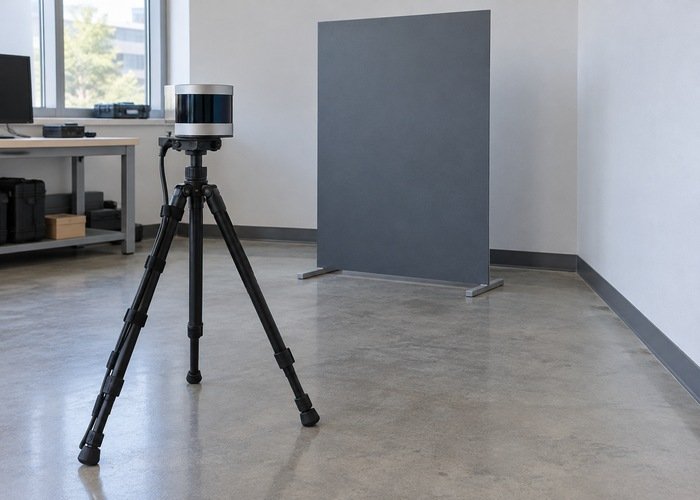
A fixed-scene procedure that separates point-cloud display persistence, scan batching and missing measurements.
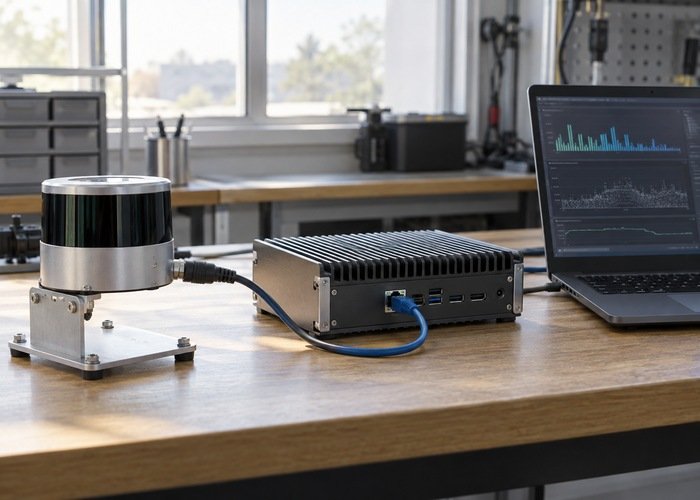
A controlled measurement worksheet for LiDAR packet arrival, cloud publication, subscriber reception and completed processing.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
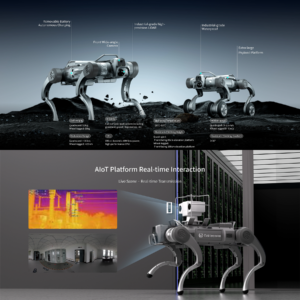 Robotic Dog-E1 Series
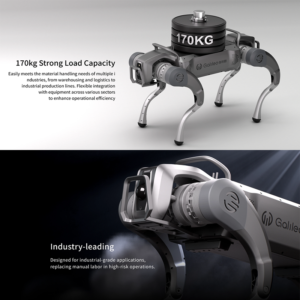 Robotic Dog-S1 Series