A boundary-by-boundary diagnostic for a valid PointCloud2 that never produces Nav2 occupied cells, with a stationary target test and evidence worksheet.
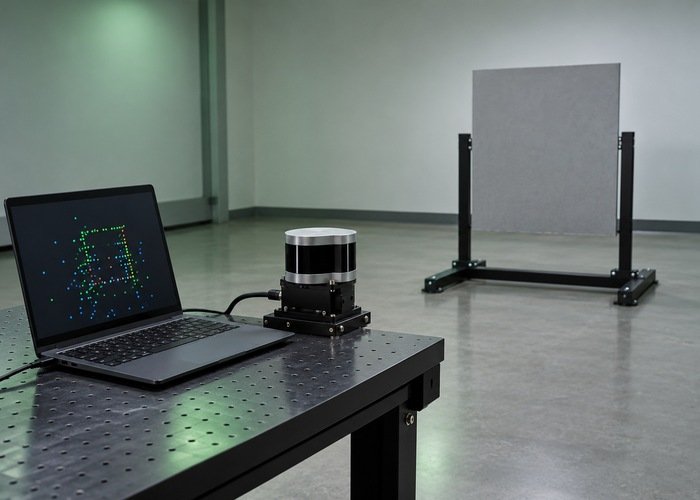
A boundary-by-boundary diagnostic for a valid PointCloud2 that never produces Nav2 occupied cells, with a stationary target test and evidence worksheet.
A field-contract and replay checklist for preserving per-point timing when recording LiDAR and IMU messages.
A fixed-scene procedure that separates point-cloud display persistence, scan batching and missing measurements.
A controlled measurement worksheet for LiDAR packet arrival, cloud publication, subscriber reception and completed processing.
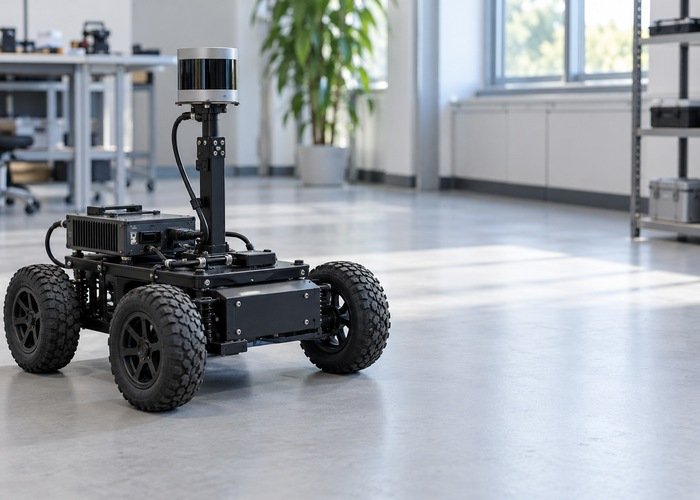
Inspect endpoint policies and test compatible reception before treating a silent ROS 2 LiDAR subscriber as a sensor failure.
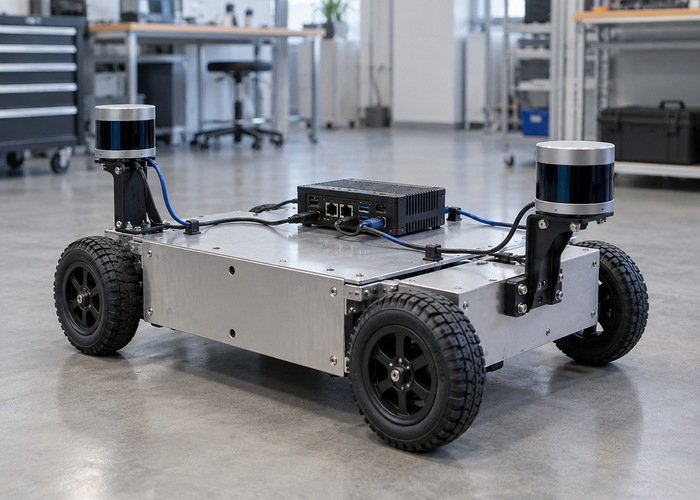
An address, routing and sensor-identity checklist for two Ethernet LiDARs connected to independent host interfaces.
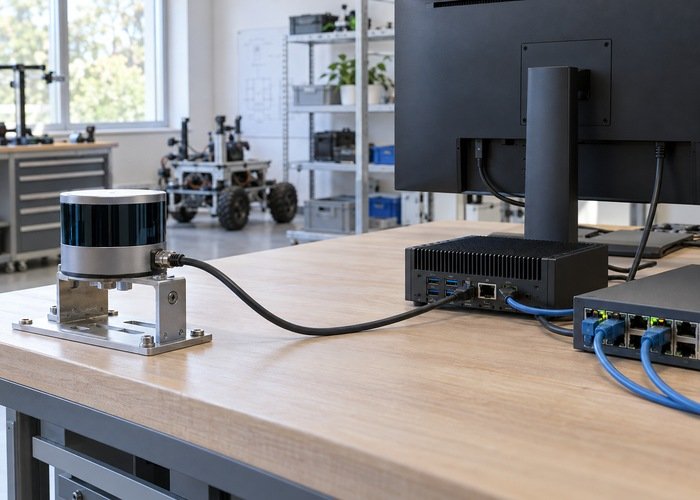
A practical diagnostic path for LiDAR data that appears in a viewer but does not reach the ROS driver.

automotive LiDAR connector practical guide with field checks, setup decisions and LidarStar sensor-selection notes.

carrier board LiDAR integration practical guide with field checks, setup decisions and LidarStar sensor-selection notes.

3D LiDAR profiling practical guide with field checks, validation workflow, and application guidance.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
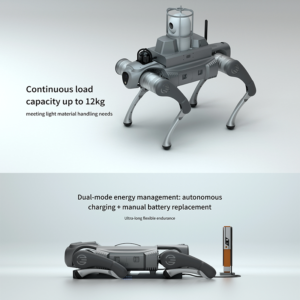 Robotic Dog-C1 Series
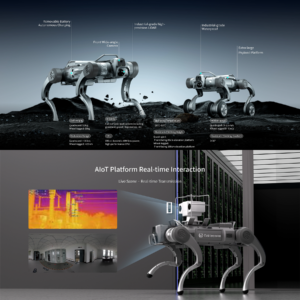 Robotic Dog-E1 Series
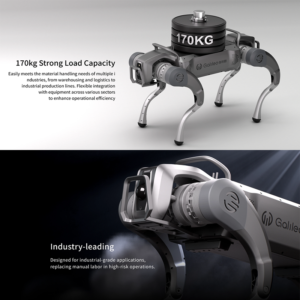 Robotic Dog-S1 Series