Separate Nav2 costmap update cadence from published visualization traffic before changing frequencies, full-map settings or LiDAR pipeline parameters.
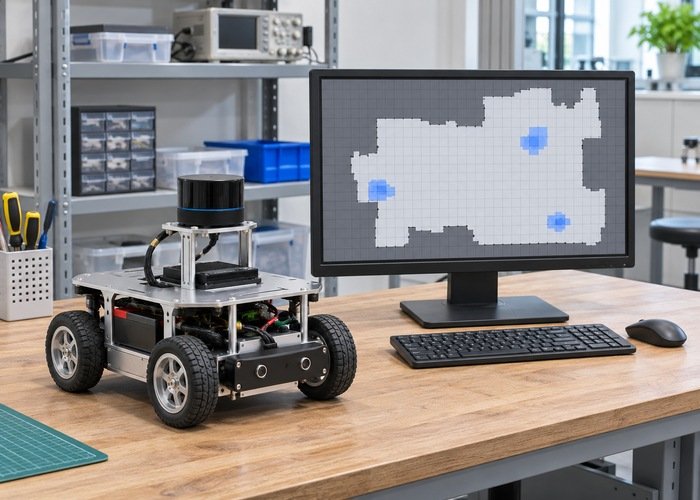
Separate Nav2 costmap update cadence from published visualization traffic before changing frequencies, full-map settings or LiDAR pipeline parameters.
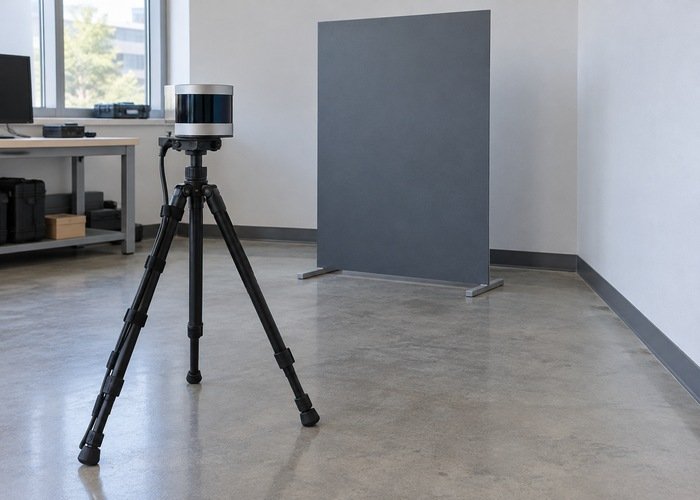
A fixed-scene procedure that separates point-cloud display persistence, scan batching and missing measurements.
2D LiDAR sensor in ROS 2 practical guide with setup checks, source-backed engineering context, field validation tables, and application guidance.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
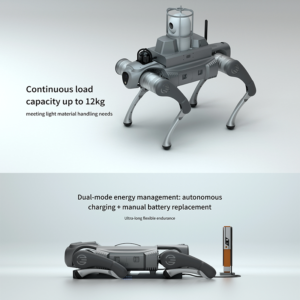 Robotic Dog-C1 Series
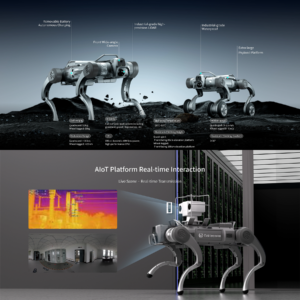 Robotic Dog-E1 Series
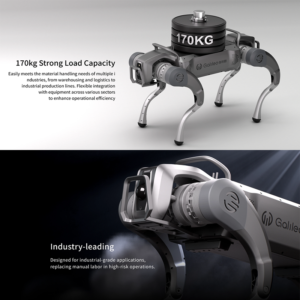 Robotic Dog-S1 Series