Reject confirmed robot-body returns without hiding useful nearby targets. Inspect the plugin geometry, frame, raw indices and downstream handling before accepting a filter.
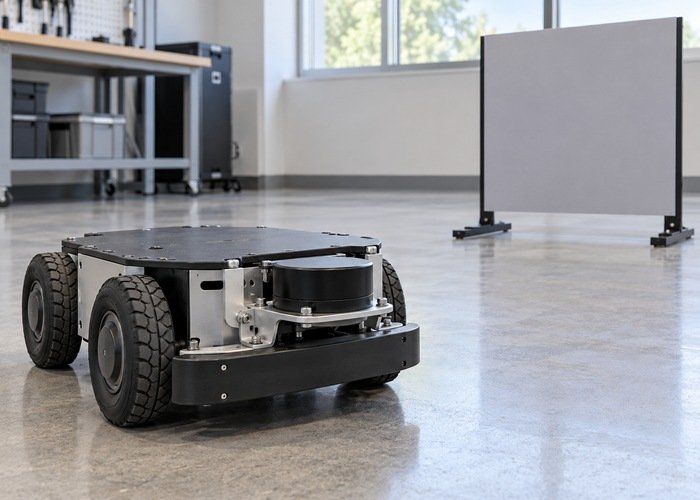

Reject confirmed robot-body returns without hiding useful nearby targets. Inspect the plugin geometry, frame, raw indices and downstream handling before accepting a filter.
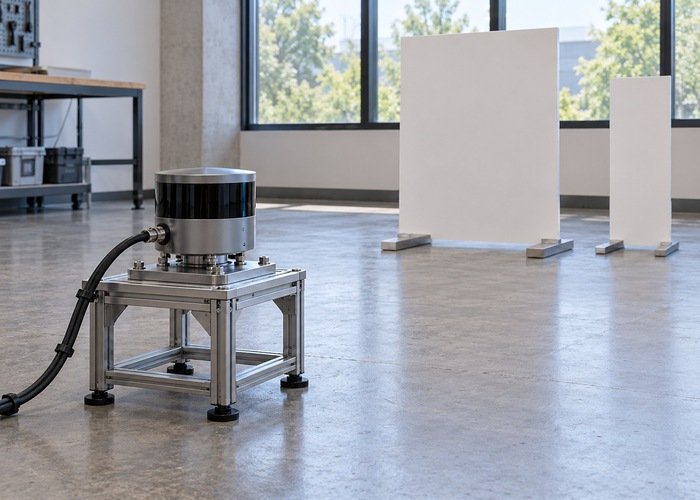
Trace the first projection stage that rejects a known target. Distinguish no messages, empty scan bins, and downstream rejection before replacing a working LiDAR.

LiDAR data format practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
 Robotic Dog-E1 Series
 Robotic Dog-S1 Series


