A cold-versus-sustained workload experiment for investigating Jetson LiDAR latency without assuming every warm slowdown is thermal throttling.
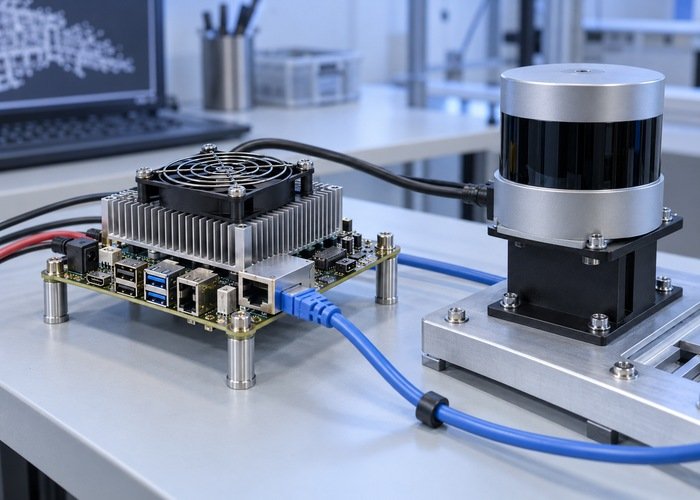
A cold-versus-sustained workload experiment for investigating Jetson LiDAR latency without assuming every warm slowdown is thermal throttling.
A route-by-route CSI and downstream workload budget with explicitly illustrative calculations and a concurrent camera-capture validation matrix.
A runtime comparison matrix and replayable evidence package for GMSL cameras that capture through V4L2 but fail in the intended Argus path.
A physical-to-logical route worksheet and distinct-target test for two GMSL cameras that appear to produce the same stream.
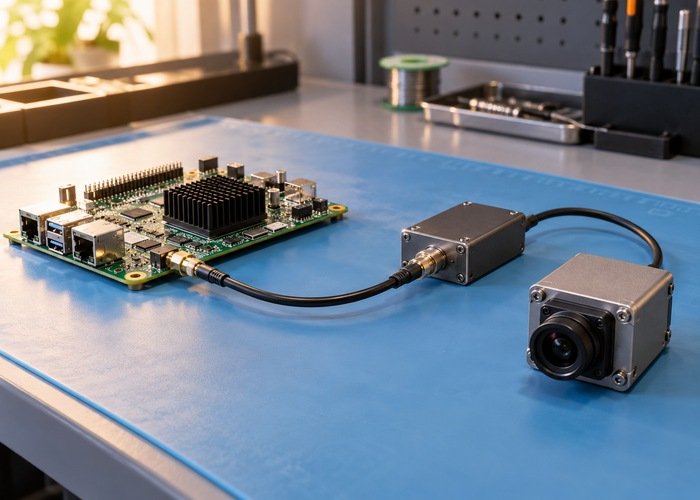
A pre-order compatibility worksheet connecting GMSL hardware identities, Jetson carrier support, release-pinned BSP packages and application-level capture evidence.
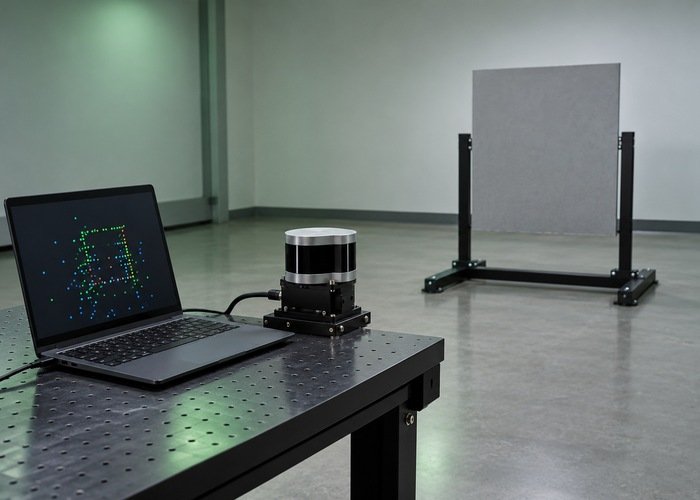
A boundary-by-boundary diagnostic for a valid PointCloud2 that never produces Nav2 occupied cells, with a stationary target test and evidence worksheet.
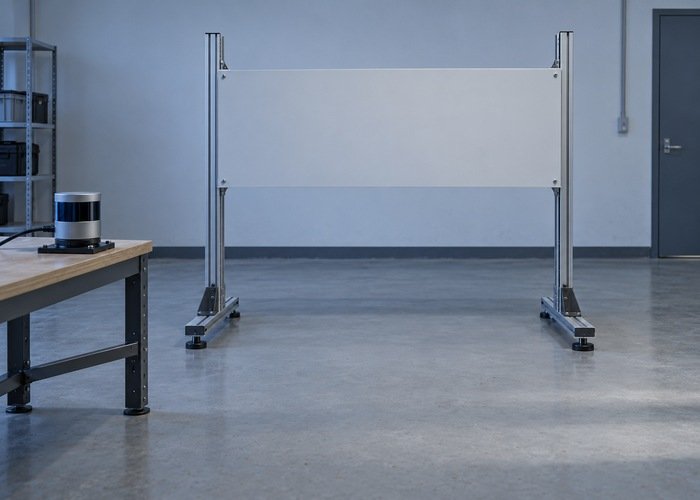
A source-to-grid diagnostic and measured target-height matrix for overhanging obstacles visible in LiDAR but missing from a Nav2 costmap.
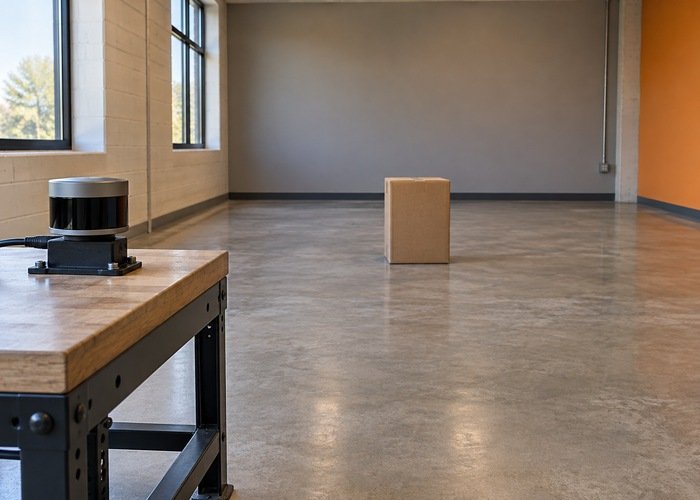
A layered diagnostic for stale LiDAR obstacles in Nav2, connecting fresh observations and clearing-ray geometry to a reproducible place-and-remove test.
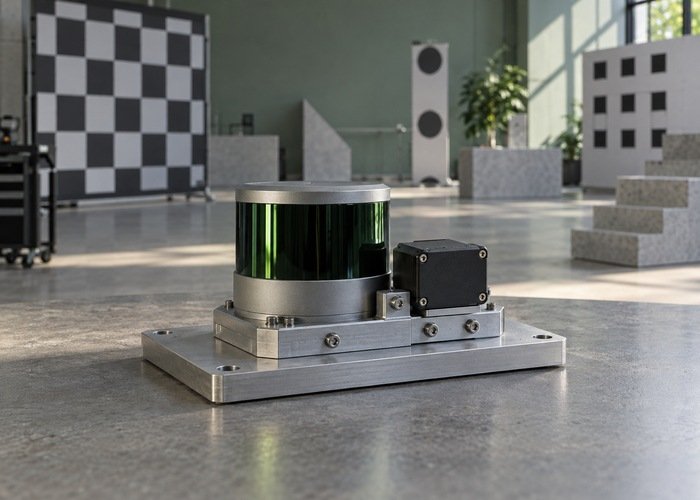
A capture-sufficiency worksheet for LiDAR–IMU initialization, with method-specific excitation feedback and independent validation of a frozen calibration result.
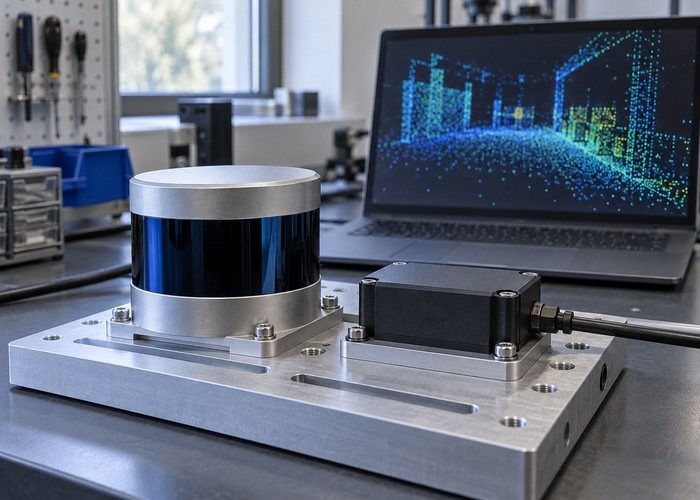
A practical field-contract worksheet and repeat-test procedure for diagnosing FAST-LIO motion smear caused by incorrect point-time interpretation.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
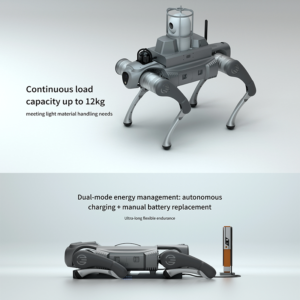 Robotic Dog-C1 Series
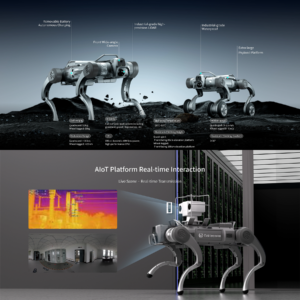 Robotic Dog-E1 Series
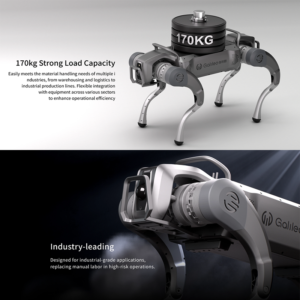 Robotic Dog-S1 Series