Match the projected pixel domain to the exact image stream. Compare raw and rectified camera models, dimensions and processing with unchanged sensor extrinsics.
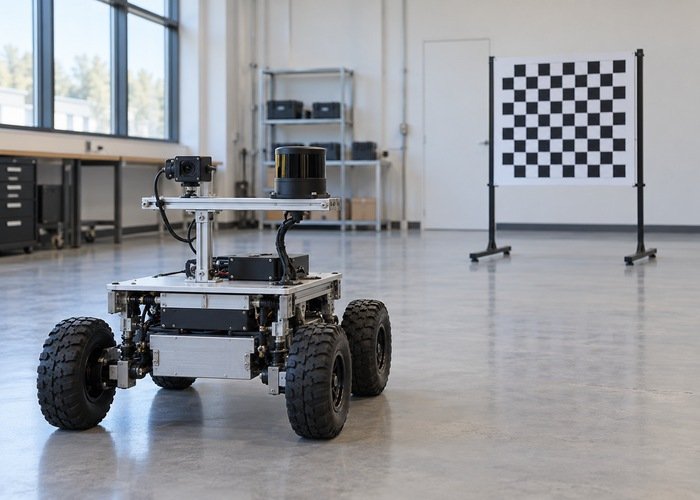

Match the projected pixel domain to the exact image stream. Compare raw and rectified camera models, dimensions and processing with unchanged sensor extrinsics.
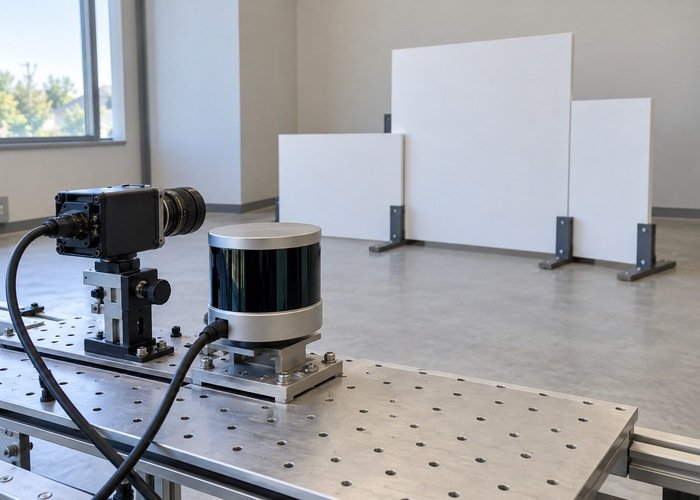
Check frame conventions and the projection chain before collecting another calibration dataset. Use asymmetric targets and intermediate coordinates to isolate interpretation errors.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
 Robotic Dog-E1 Series
 Robotic Dog-S1 Series


