Check frame conventions and the projection chain before collecting another calibration dataset. Use asymmetric targets and intermediate coordinates to isolate interpretation errors.
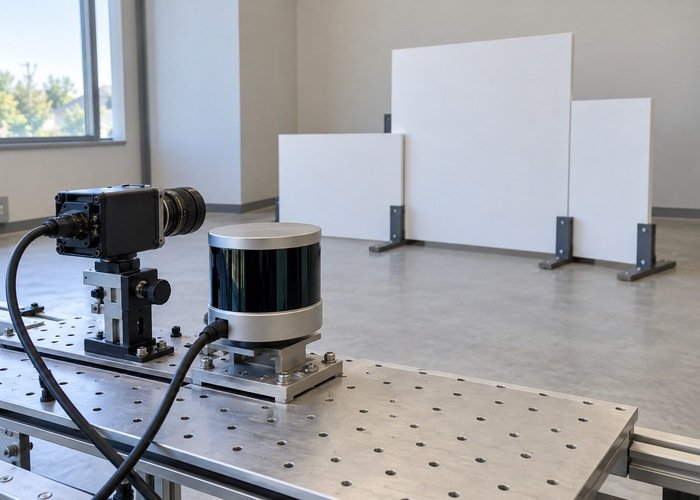

Check frame conventions and the projection chain before collecting another calibration dataset. Use asymmetric targets and intermediate coordinates to isolate interpretation errors.

LiDAR robotics integration practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
 Robotic Dog-E1 Series
 Robotic Dog-S1 Series


