Draw measurement provenance at variable level. Identify shared encoder or IMU observations before interpreting a smooth trajectory and small covariance as confidence.
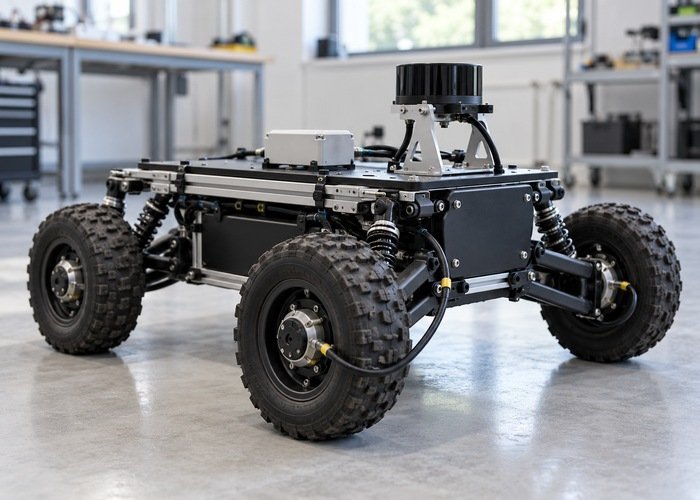
Draw measurement provenance at variable level. Identify shared encoder or IMU observations before interpreting a smooth trajectory and small covariance as confidence.

robot LiDAR sensor fusion practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
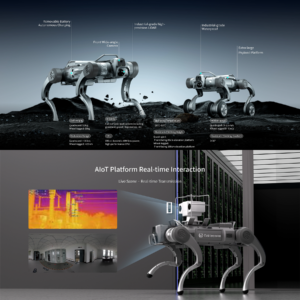 Robotic Dog-E1 Series
 Robotic Dog-S1 Series