A visible image topic does not prove rectifier delivery. Audit payload types, transport selection, decoding and camera-info pairing boundary by boundary.
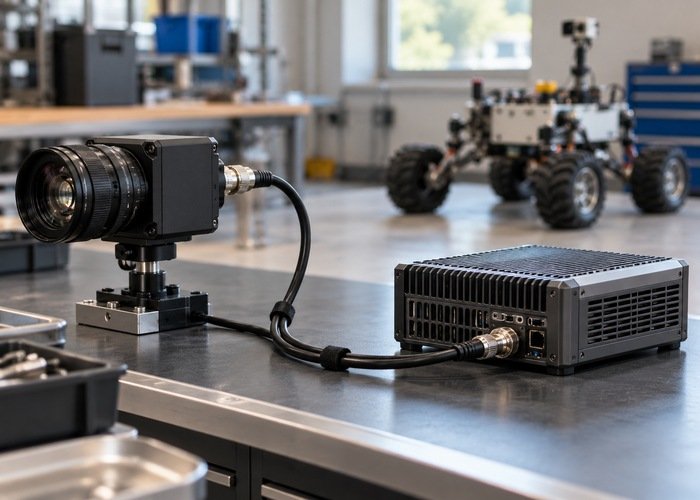

A visible image topic does not prove rectifier delivery. Audit payload types, transport selection, decoding and camera-info pairing boundary by boundary.
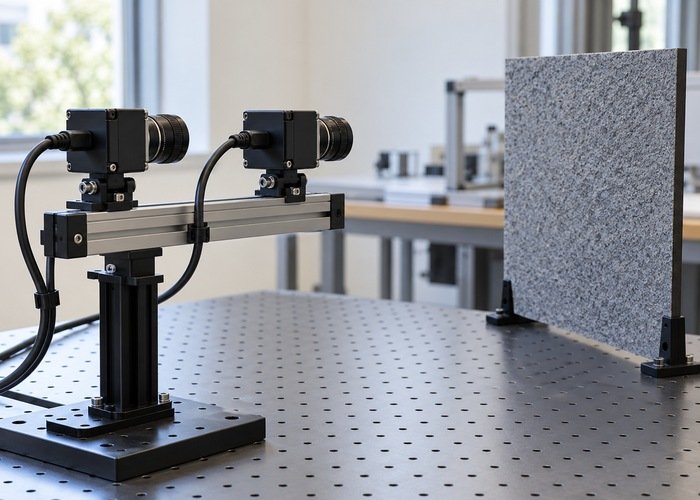
Separate depth quantity, storage type and physical units. Trace original and converted values before changing stereo calibration or camera geometry.
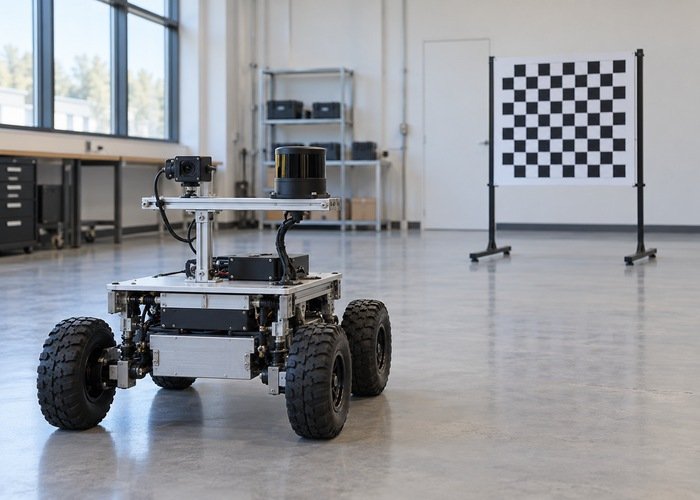
Match the projected pixel domain to the exact image stream. Compare raw and rectified camera models, dimensions and processing with unchanged sensor extrinsics.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
 Robotic Dog-C1 Series
 Robotic Dog-E1 Series
 Robotic Dog-S1 Series


