Draw measurement provenance at variable level. Identify shared encoder or IMU observations before interpreting a smooth trajectory and small covariance as confidence.
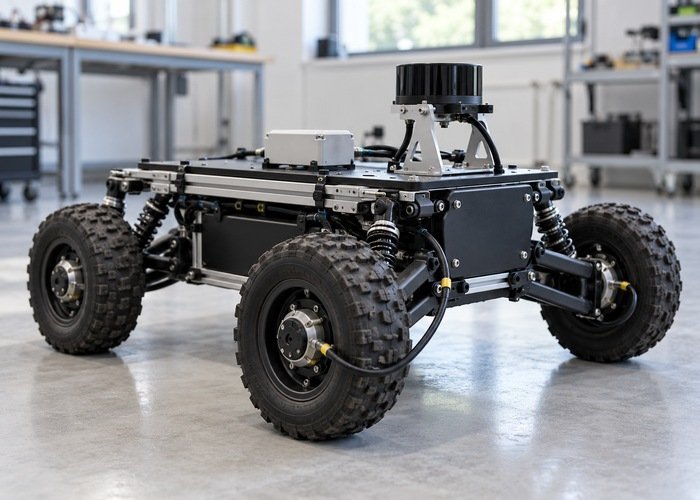
Draw measurement provenance at variable level. Identify shared encoder or IMU observations before interpreting a smooth trajectory and small covariance as confidence.
A capture-sufficiency worksheet for LiDAR–IMU initialization, with method-specific excitation feedback and independent validation of a frozen calibration result.

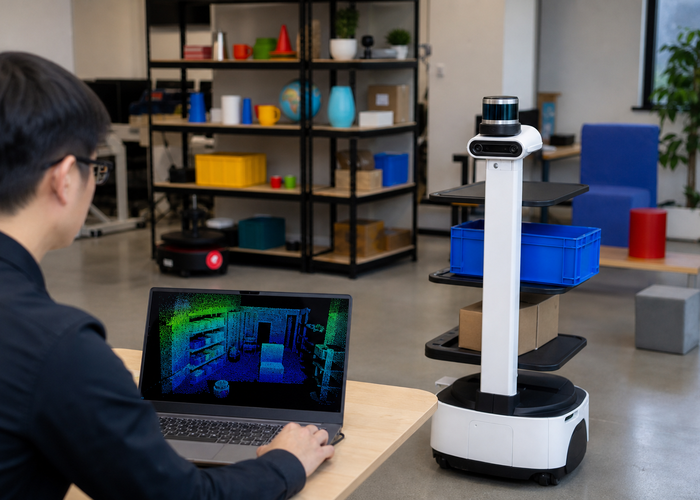
robot LiDAR sensor fusion practical guide with field checks, setup decisions and LidarStar sensor-selection notes.
6D and Full-Color LiDAR practical guide with field checks and application guidance.
native color LiDAR sensors practical guide with field checks and application guidance.
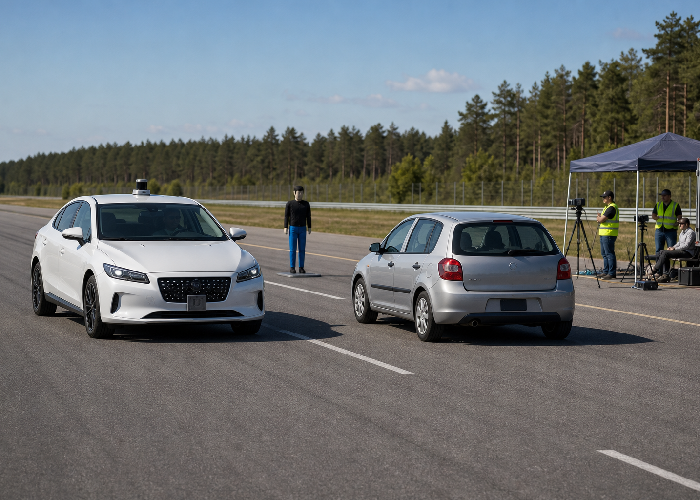
FMCW LiDAR vs imaging radar practical guide with field checks and application guidance.
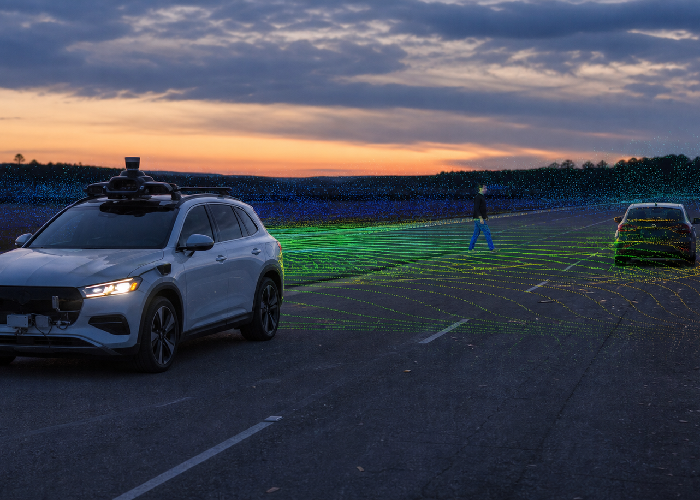
automotive LiDAR practical guide with field checks and application guidance.
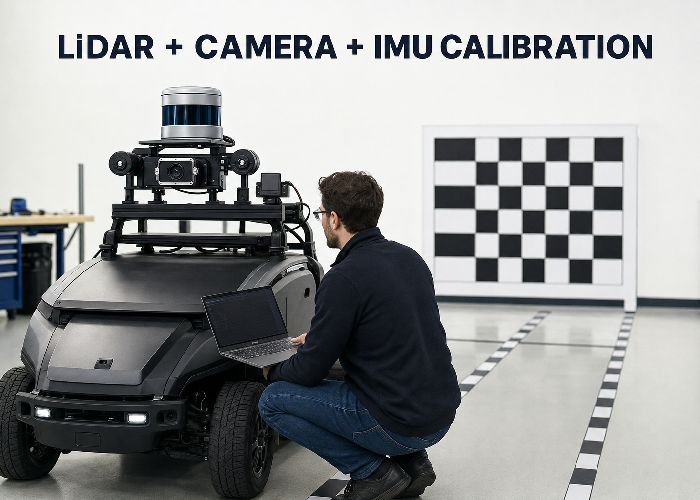
Use this practical LiDAR, camera and IMU calibration workflow to plan data collection, estimate transforms, verify timing, and catch mounting or projection errors before deployment.

2D LiDAR vs ultrasonic sensors practical guide with field checks and application guidance.
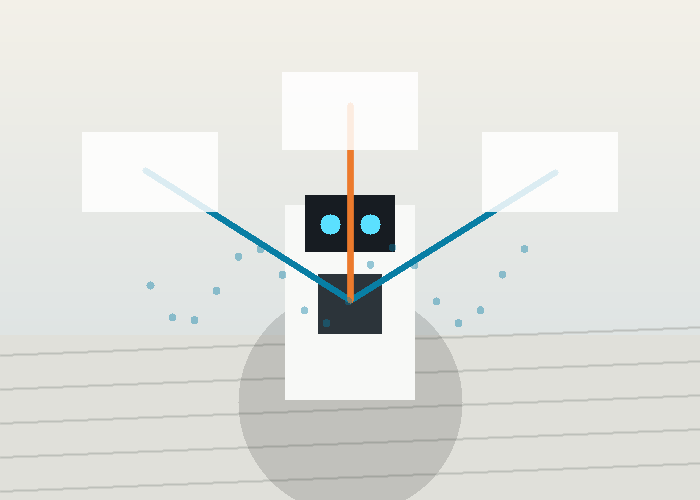
2D LiDAR + IMU + camera sensor fusion practical guide with setup checks, source-backed engineering context, field validation tables, and application guidance.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
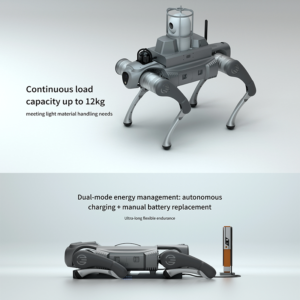 Robotic Dog-C1 Series
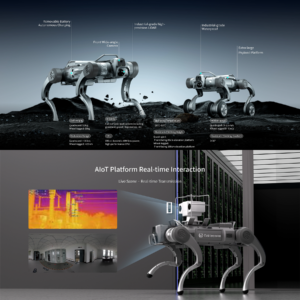 Robotic Dog-E1 Series
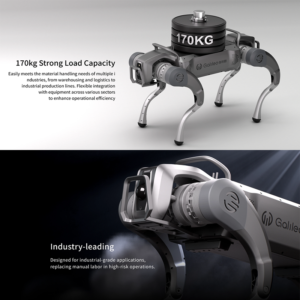 Robotic Dog-S1 Series