A boundary-by-boundary diagnostic for a valid PointCloud2 that never produces Nav2 occupied cells, with a stationary target test and evidence worksheet.
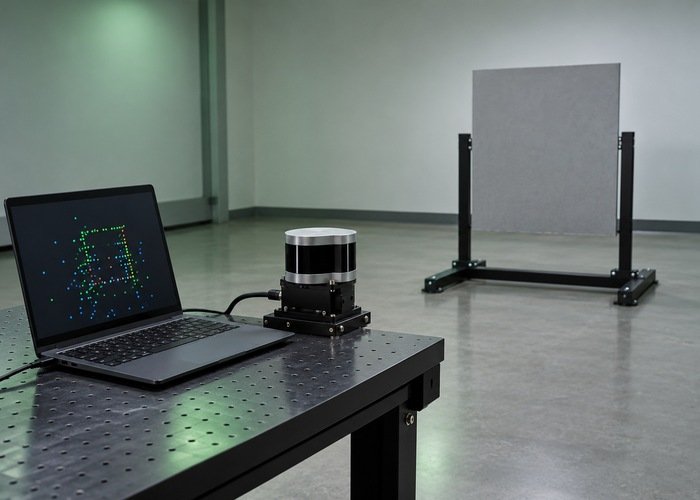
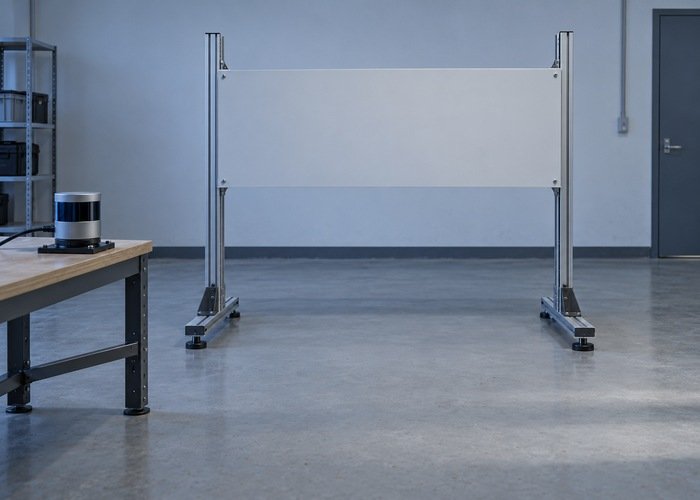
A boundary-by-boundary diagnostic for a valid PointCloud2 that never produces Nav2 occupied cells, with a stationary target test and evidence worksheet.
A source-to-grid diagnostic and measured target-height matrix for overhanging obstacles visible in LiDAR but missing from a Nav2 costmap.
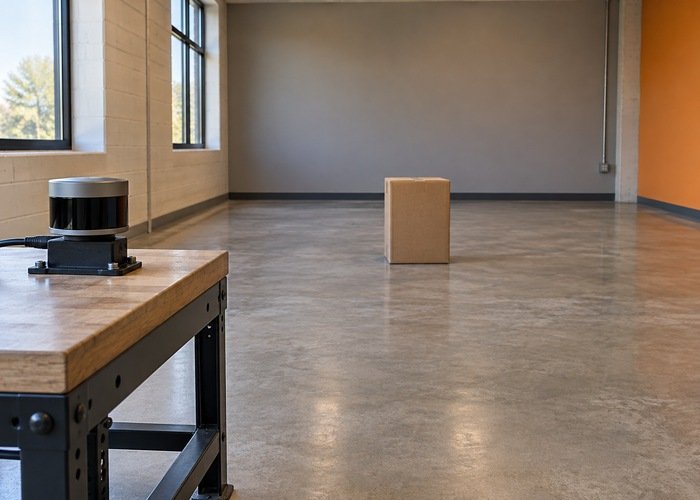
A layered diagnostic for stale LiDAR obstacles in Nav2, connecting fresh observations and clearing-ray geometry to a reproducible place-and-remove test.
 ST-X07
 ST-P136 FPV Drone
Original price was: $968.00.$958.00Current price is: $958.00.
 ST-X07 FPV Drone
Original price was: $866.00.$862.00Current price is: $862.00.
 ST-X10 FPV Drone
Original price was: $642.00.$638.00Current price is: $638.00.
 RoboSense B-peael
Original price was: $2,300.00.$2,015.00Current price is: $2,015.00.
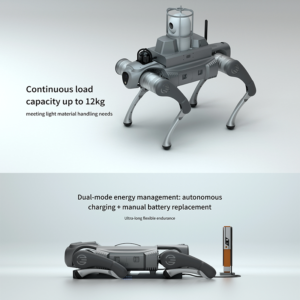 Robotic Dog-C1 Series
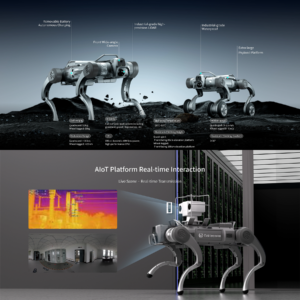 Robotic Dog-E1 Series
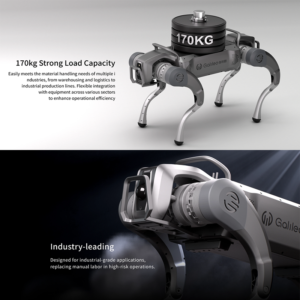 Robotic Dog-S1 Series